Runway has made Praxis-1, an open-weight model for controlling robots, available to everyone. Alongside the weights, it released inference and fine-tuning code under the Apache 2.0 license, allowing developers to adapt the model to their own hardware, including for commercial use. The company first introduced it in September.
A model that predicts video and actions
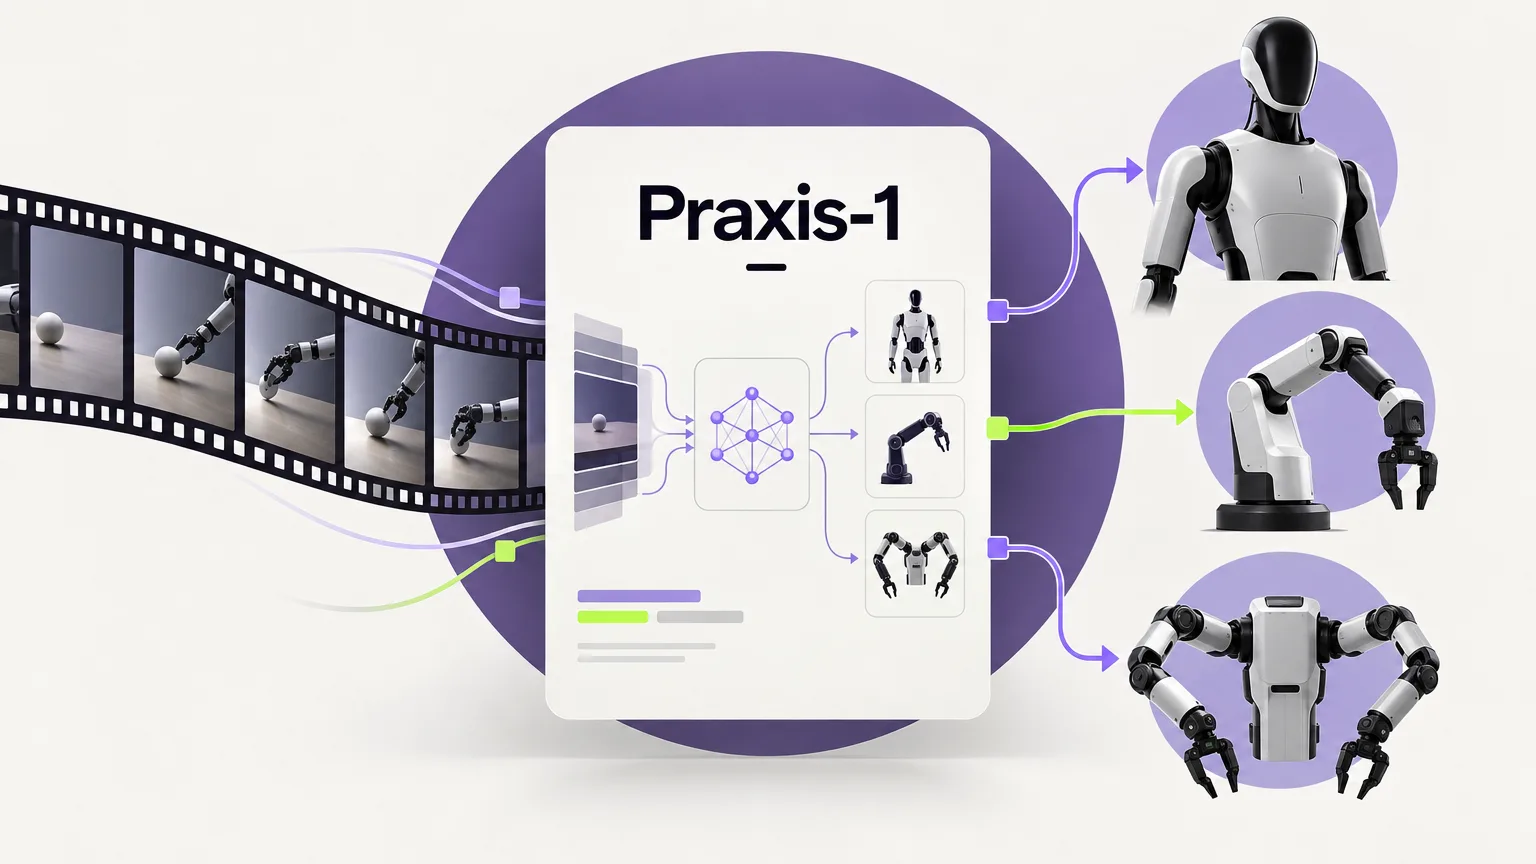
Praxis-1 is a mixture-of-experts diffusion transformer with 27 billion parameters. It predicts video and actions together and builds on the same large-scale video pretraining as Runway’s general world models.
According to Runway, the model learns from video how objects behave and how tasks unfold. The company’s research also found that, when evaluating robotic policy performance, pretraining on web video produced the same results as pretraining on video of teleoperated robots.
Results on RoboLab-120 and SimplerEnv
On NVIDIA’s RoboLab-120 leaderboard, Praxis-1 achieved a 46.2% success rate across 1,200 episodes, according to Runway. FLUX 3 Action scored 42.9%, Cosmos3 Nano 36.8% and π0.5 28.0%.
Runway also reported a result for Google’s RT-1 robot, which did not appear in the model’s original training data. After fine-tuning for that robot, Praxis-1 achieved an 80.0% success rate on SimplerEnv, compared with 52.4% for the original RT-1 policy.
Adapting the model to different robots
Partners Noble Machines, Standard Bots and Ultra have run the model on their own hardware. Their platforms included a walking humanoid robot, a six-axis industrial arm and a dual-arm warehouse robot.
According to Runway, its partners adapted a single model checkpoint to different platforms with light fine-tuning. The LoRA method allows developers to adapt the model to their own robotic platform, cameras and tasks without retraining the entire model.
Where Praxis-1 is available
The model is available on GitHub, on Hugging Face with native LeRobot support, and in vLLM-Omni; Reactor offers hosted inference. Full fine-tuning is available alongside LoRA. Developers can also try the model on Runway Dev and use hands-on NeMo Automodel tutorials for post-training on specific use cases.
Runway says the model supports NVIDIA hardware ranging from H100 and B200 data center GPUs to RTX 5090 and RTX PRO 6000 workstation GPUs, as well as Jetson Thor directly on a robot.